Overview
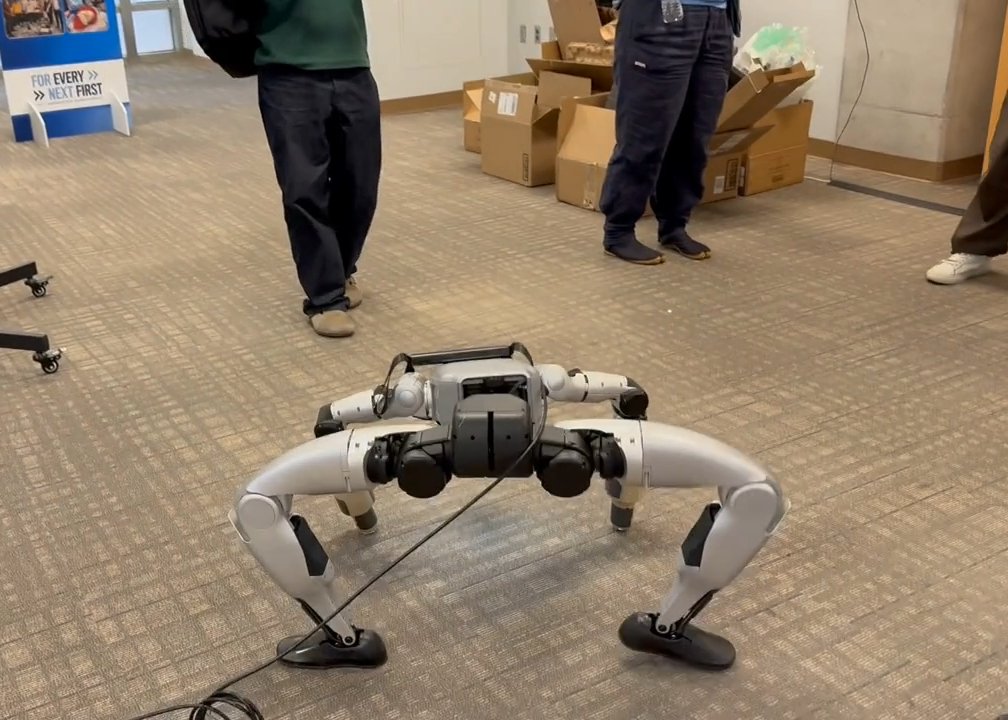
We enable a Unitree G1 humanoid (29-DoF) to transition from standing into a four-limbed crawling posture, crawl forward and turn, and return to standing. Two policies, one for the stand ↔ crawl transition and one for crawling (with two gait styles), are trained in mjlab with PPO and switched by a state machine with safety gates at each hand-over. The forearms serve as front legs: 3D-printed wrist braces lock the wrists and extend them into rounded feet.
Code, deployable policies, and hardware files are available on GitHub.
Contributors
Geeta Chandra Raju Bethala (demo) and Krishna Murthy Jatavallabhula (video)