Overview
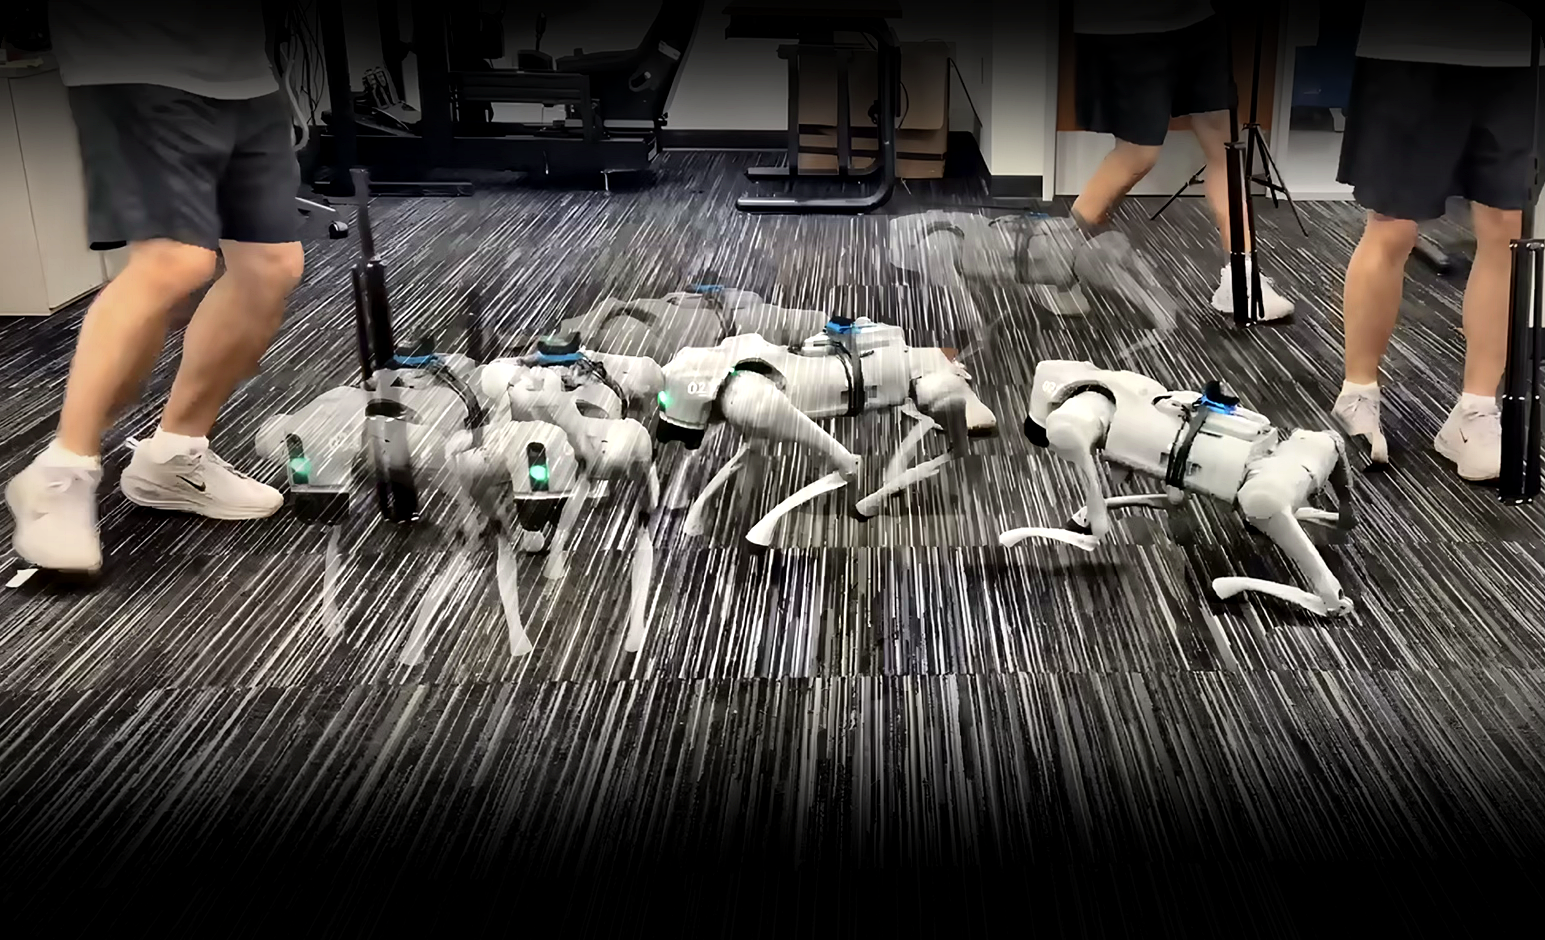
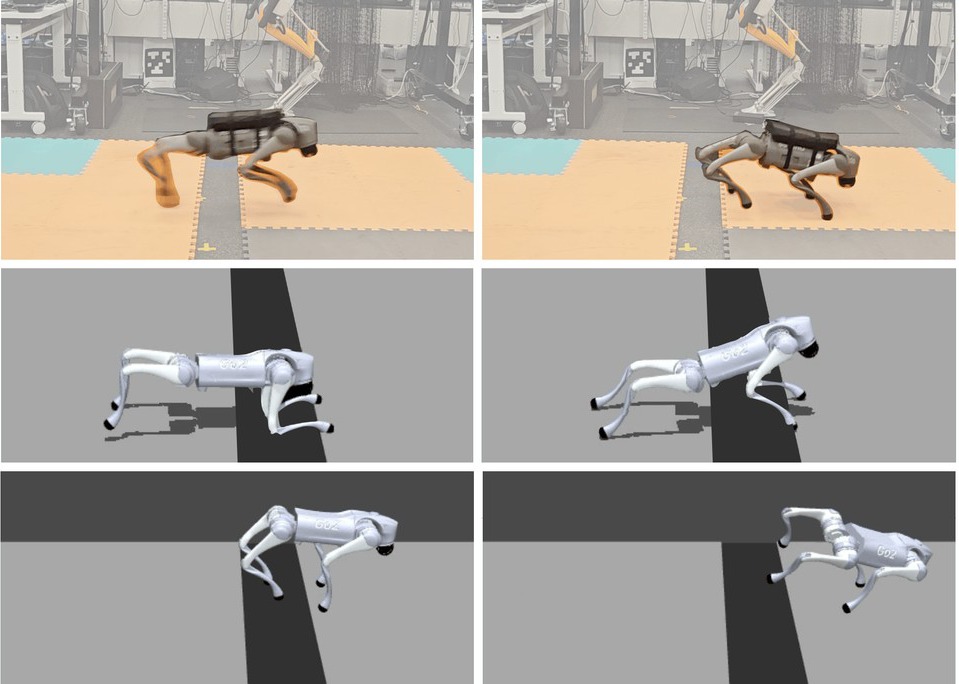
We study strict reach-avoid-stay (sRAS) control, which requires safely reaching a target and remaining there indefinitely after first entry. We present a Q-control barrier function filter for high-dimensional black-box systems with bounded uncertainty, merging a stay value encoding safe permanent residence with a reach-avoid value encoding safe target reachability. Our approach requires no knowledge of system dynamics, structural properties, or hand-crafted barriers, and we validate it on quadruped gap-jumping experiments (simulated and physical) and simulated autonomous racing scenarios.
Contributors
Donggeon David Oh, Duy P. Nguyen, Gongkai Yuan, Qingchen Li, Jaime Fernández Fisac, and Haimin Hu